OpenGate
From perception to post-training, a deployment-audit gate
Given a small deployment vocabulary V,
OpenGate audits any detector's episode-level behavior: EpisodicAP (in-vocab accuracy) and
OOV-FP (out-of-vocab hallucination) → PASS/FAIL — and reads WorldEngine's own
nuPlan eval output through the same gate.


01Real GPU numbers — official 3D stack (nuScenes mini-val)
DETR3D mAP
0.3315
official weights · mmdet3d 1.x · mini-val
DETR3D NDS
0.3956
nuScenes detection score
FCOS3D mAP
0.294
official weights · mini-val
FCOS3D NDS
0.322
nuScenes detection score
Hardware
RTX 5070
CUDA 12.8 · torch 2.11 · mmcv 2.1.0 (Windows build)
Both are real runs of MMDetection3D official weights on the official nuScenes mini-val protocol —
the same AlgEngine stack WorldEngine builds on. Recipes:
DETR3D_GPU_RESULT ·
FCOS3D_GPU_RESULT.
02Real driving-scene gate (nuScenes mini, 6 cameras)
EpisodicAP
17.54
full-mini 2,424 views · YOLO-World · 6-camera pool
OOV-FP
0.240
driving scenes are naturally OOV-dense
Gate
PASS
EpisodicAP ≥ 10 · OOV-FP ≤ 0.45
Key insight
Views change conclusions
front-only overestimates; 60-view baseline EpisodicAP 13.47
Full-mini run: 404 keyframes × 6 cams = 2,424 real views, YOLO-World 10-class deploy vocab; 3D GT projected to 2D via the repo's view-index builder. 60-view sampled baseline (EpisodicAP 13.47 / OOV-FP 0.351) documented in
DRIVING_SCENE_GATE.
03WorldEngine bridge — post-training eval → the same gate
Open-loop PDMS
88.95 → 59.83
common → rare (official table)
Closed-loop SR
88.89
rare scenarios (official table)
Production
−45.5% collision
200 km zero intervention
Bridge gate
PASS
synthetic eval: AP 85.7 / OOV 0.143; rare 60/0.4
worldengine_reader projects scenario-level PDMS/SR/collision/offroad onto a deployment
constraint vocabulary, so EpisodicAP becomes constraint-satisfaction rate and OOV-FP becomes violation rate.
See WORLD_ENGINE_BRIDGE.04Open-vocab detection (COCO, GPU)
| Run | Adapter | Vocab | EpisodicAP | OOV-FP | Gate |
|---|---|---|---|---|---|
| yolo_deploy | YOLO-World | 12 | 48.52 | 0.051 | PASS |
| owl_deploy | OWL-ViT-v2 | 12 | 52.04 | 0.103 | PASS |
| yolo_wide | YOLO-World | 40 | 56.79 | 0.102 | PASS |
n=120 · seed=0 · COCO val2017 subset · same gate, real weights. OWL pays for higher AP with higher OOV-FP.
Details in HARD_CURRENCY_RESULTS.
05The paper stack, mounted
| Stage | Papers | Mounted as |
|---|---|---|
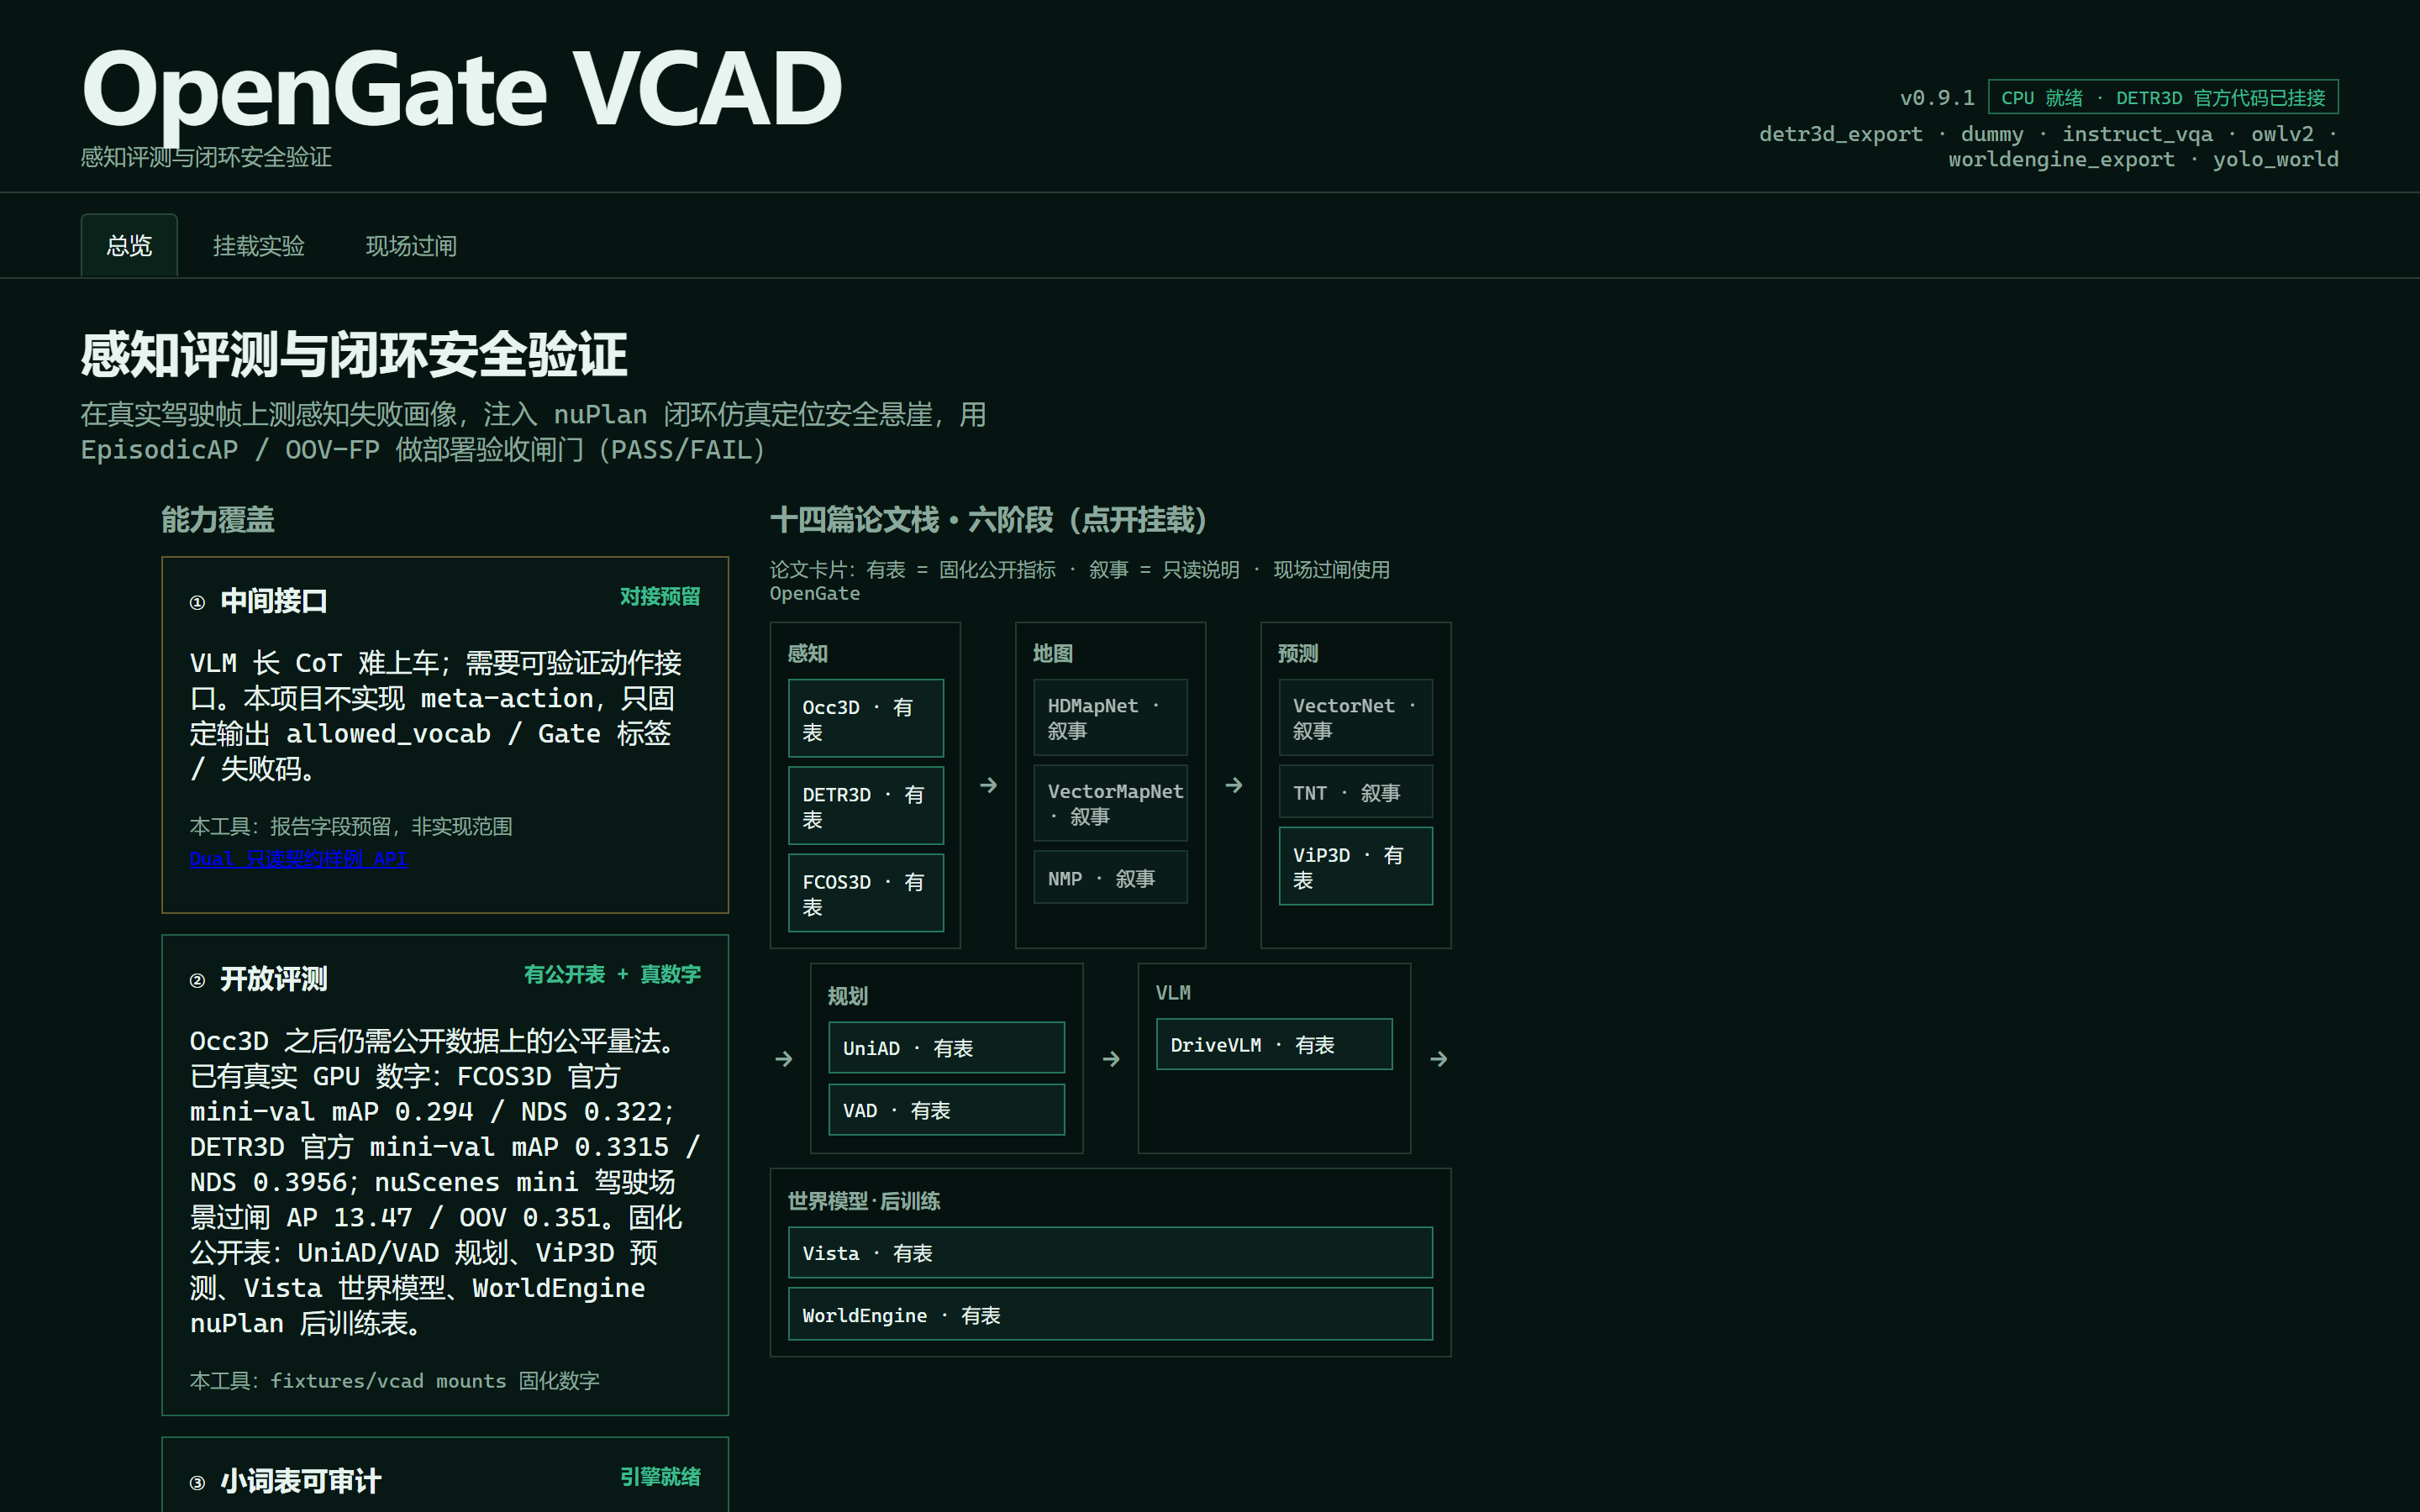
| 感知 | Occ3D · DETR3D · FCOS3D | curated + real GPU numbers |
| 地图 | HDMapNet · VectorMapNet · NMP | narrative + map-vocab analogy |
| 预测 | VectorNet · TNT · ViP3D | curated tables (ViP3D minADE 2.03) + analogy |
| 规划 | UniAD · VAD | curated official tables (avg L2 1.03→0.72 m) |
| VLM | DriveVLM | scene-vocab smoke + Dual interface |
| 世界模型·后训练 | Vista · WorldEngine | curated tables + nuPlan bridge |
Machine-readable stack: fixtures/vcad/overview.json.
06Research evidence — closed-loop safety frontier
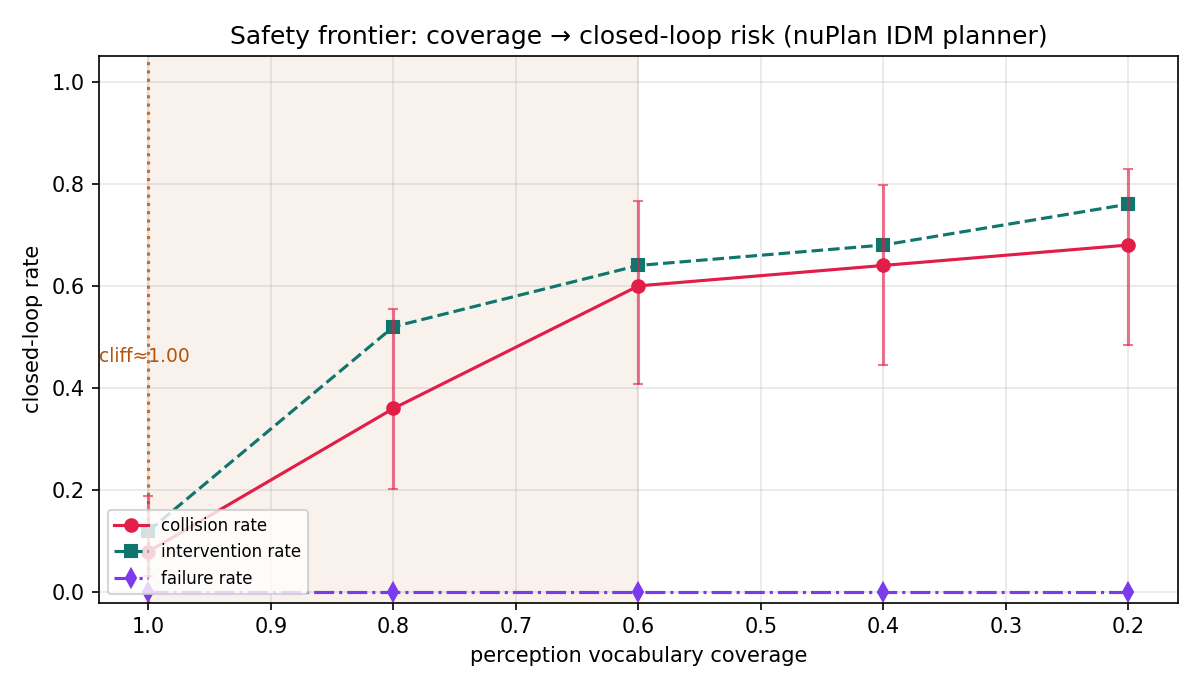
0.9.1: dual-channel attribution (miss-only / OOV-phantom-only / combined / confusion-only, N=75/tier/arm) shows the miss channel dominates (0.56 at full coverage, flat across tiers); the measured deployment axis (22 synthetic + 10 real YOLO-World closed-loop anchors) locates the gate at n_gt-weighted miss rate ≤ 0.149. H2 grid calibration (conf × profile source, 24 cells) is 24/24 miss-dominant, 48/48 consistent.
Full write-up (PDF): OpenGate 0.9.1 Technical Report.
06.5The product, running
07Why not just full-class mAP?
Full-class mAP hides what actually breaks in deployment: as the allowed vocabulary shrinks, out-of-vocabulary hallucination dominates. OpenGate audits exactly that.
- EpisodicAP — detection quality under the allowed episode vocab, not the full taxonomy.
- OOV-FP — fraction of high-score boxes whose class is outside the deploy allow-list.
- PASS/FAIL — a single gate both metrics must clear.
- Post-training — WorldEngine nuPlan outputs run through the same gate.
08Quick start
pip install -e ".[ui]"          # CPU demo + UI
python scripts/init_third_party.py   # optional: clone Zhao/MARS upstream repos
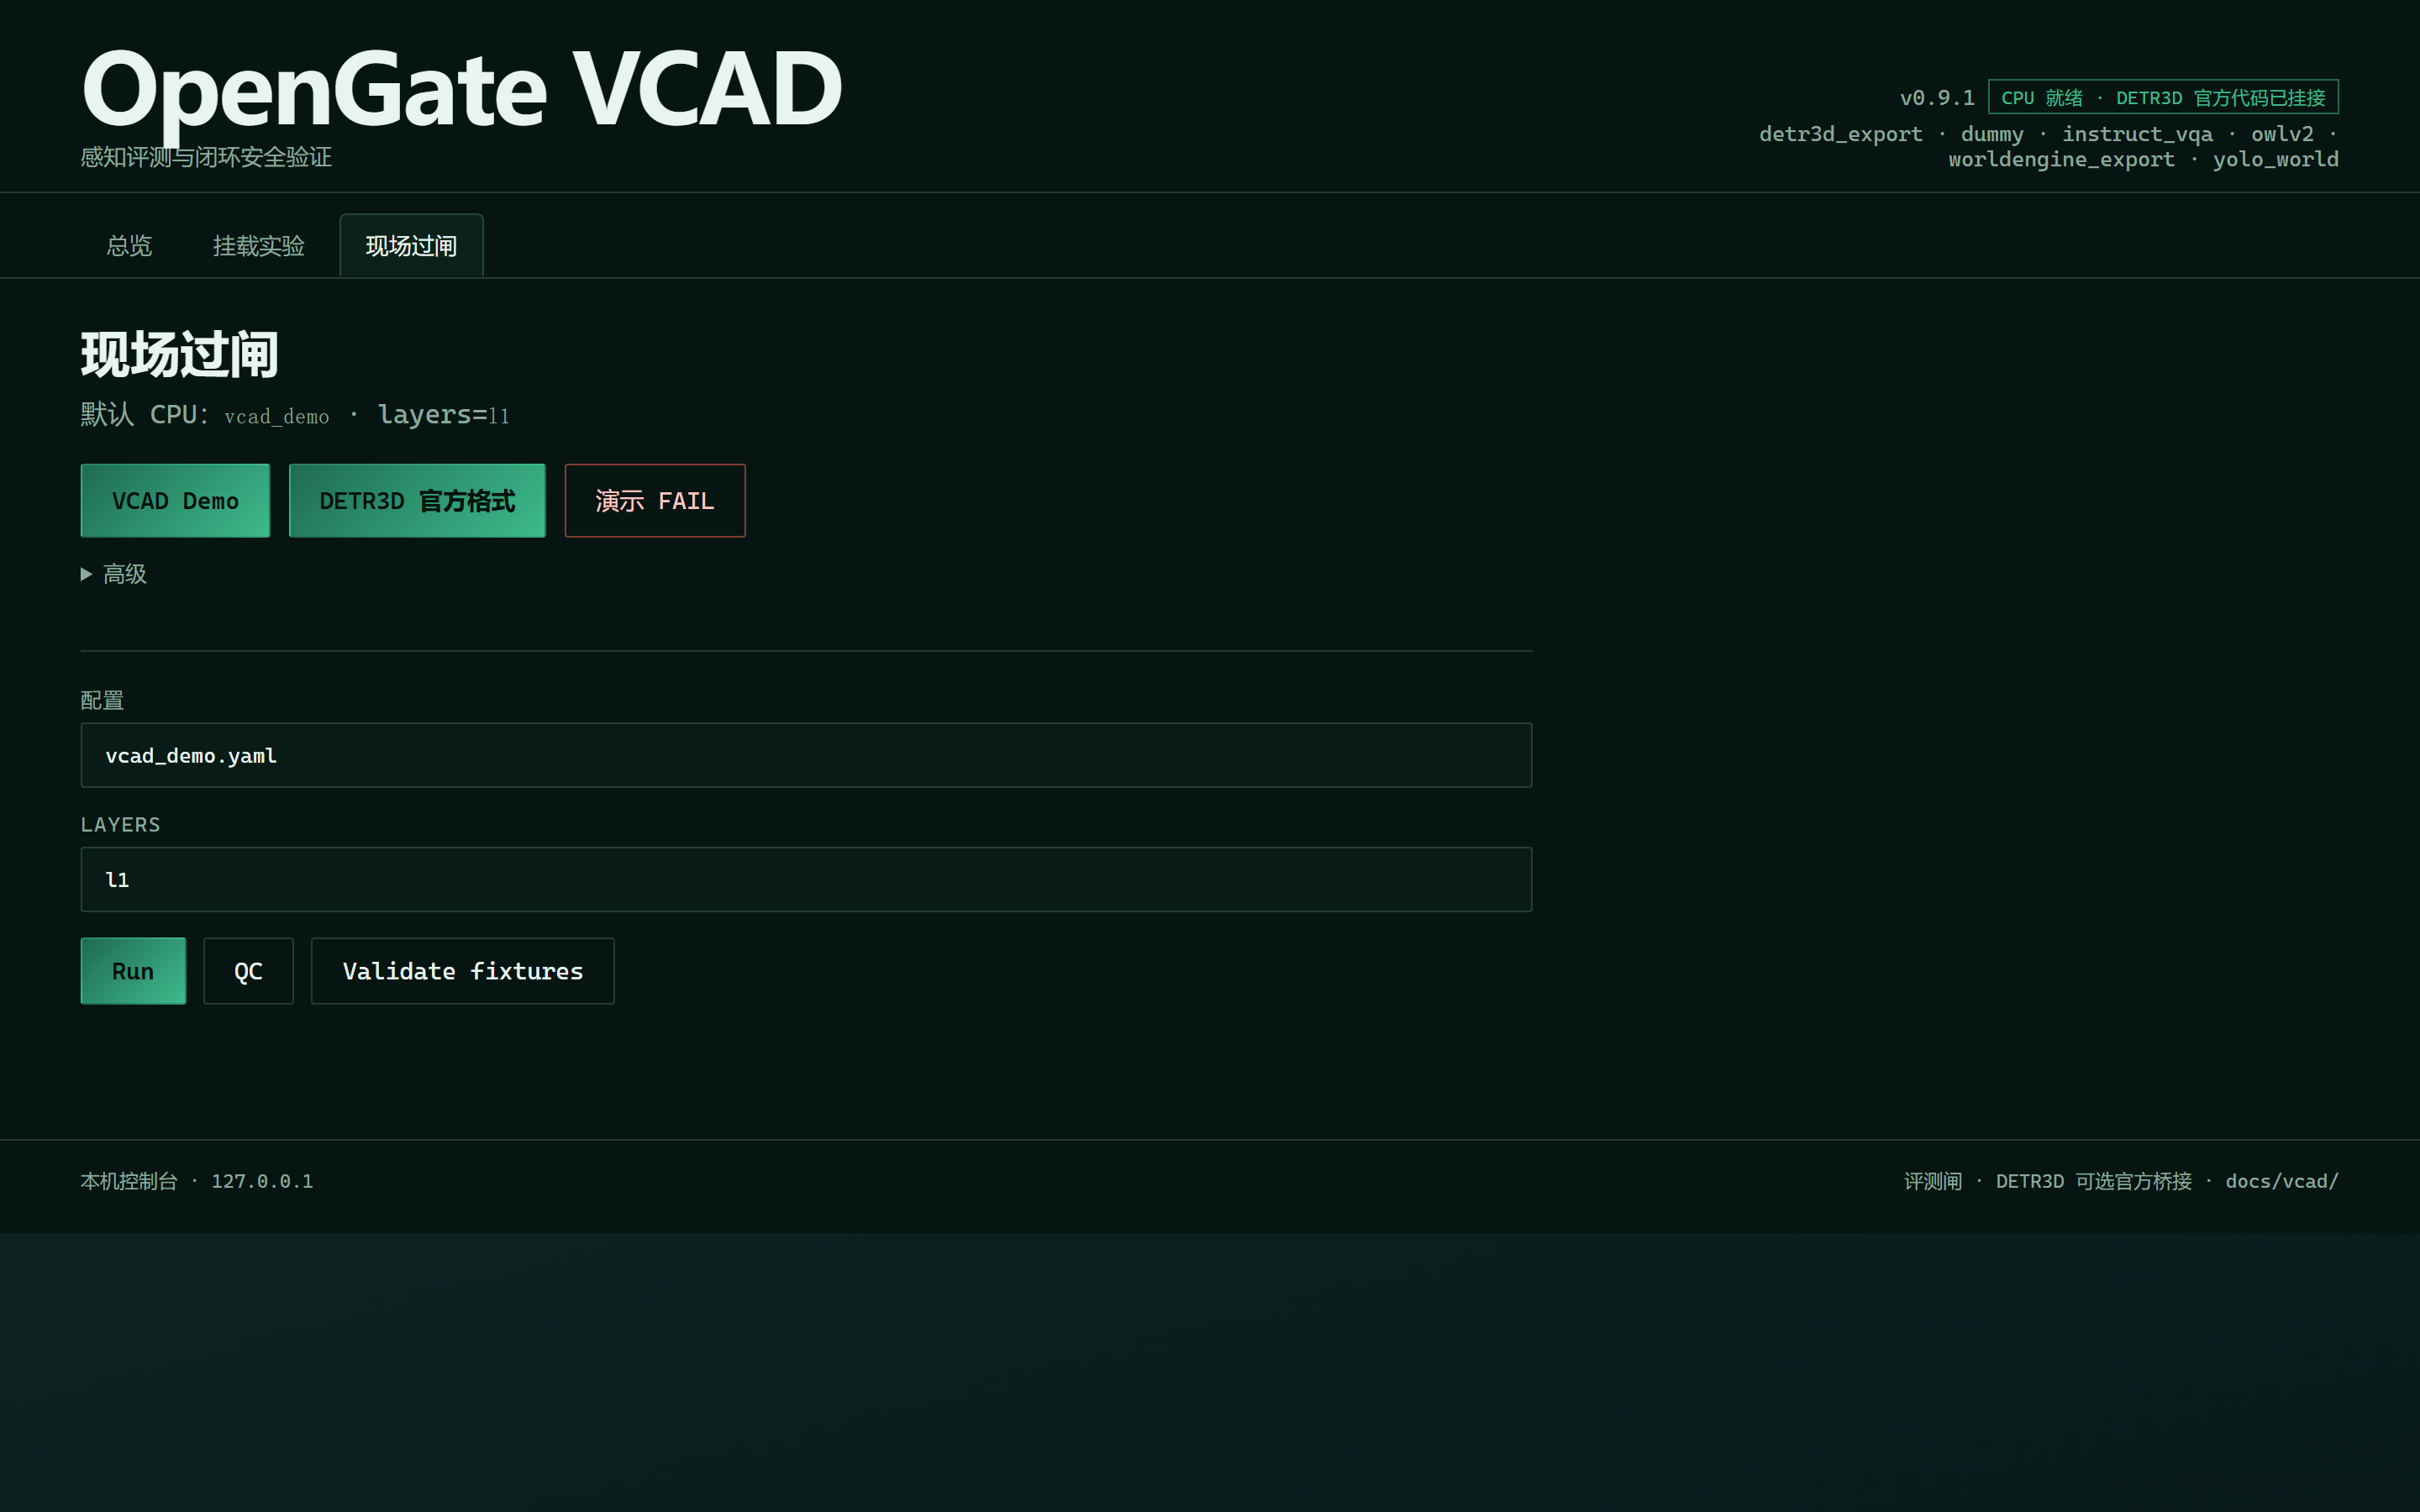
python -m opengate run -c configs/vcad_demo.yaml     # CPU demo gate
python -m opengate run -c configs/vcad_detr3d_official.yaml  # official-format export
python -m opengate run -c configs/vcad_worldengine_posttrain.yaml  # WE eval → gate
python -m opengate ui           # dashboard (overview / mounts / live gate)
Optional GPU driving vocab (YOLO-World + COCO subset) — see
docs/vcad/GPU_SETUP.md.