Headline
deployment gate α* = 0.653
Second
cliff at α = 0.4 · separation 5.5×
What this project is
Open-vocabulary grasping ships a vocabulary of object names — a deployment decision made by intuition. This project turns it into a number: profile the perception stack, inject measured failures into a closed-loop grasp simulator, and sweep vocabulary coverage α. Coverage is a safety cliff — cutting α from 1.0 to 0.2 raises grasp failure from 9.9% to 57.2%, with a statistically detected cliff at α = 0.4. For a 25% failure bound the deployment gate requires α ≥ 0.653.
Read the technical report →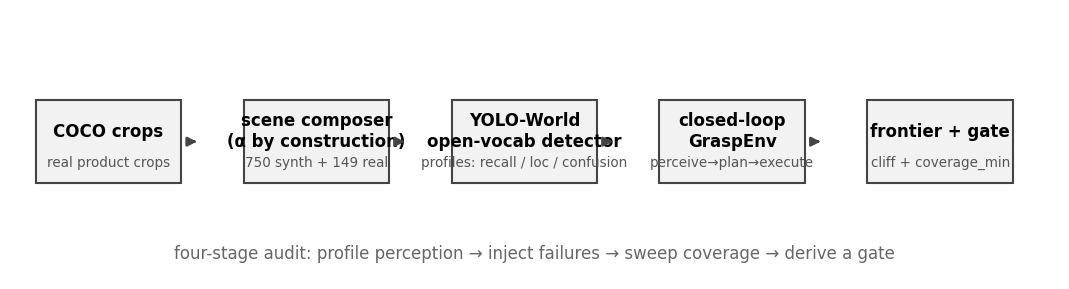
Credibility at a glance
swept vocabulary coverage α · closed-loop grasp simulator · Wilson-CI cliffs + two-proportion stats